Home / Luchs B 2.0 · Perception and autonomous navigation system
system configuration · Outdoor autonomous movement
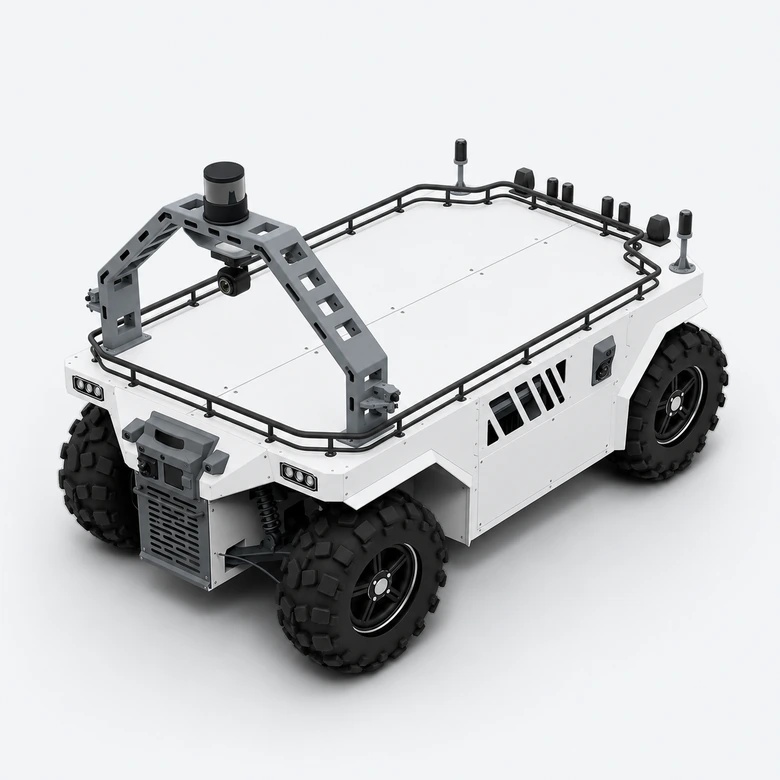
Luchs B 2.0 · Perception and autonomous navigation system
11 SENSING main cameras, independent fusion positioning, 2 ATX, 4 FTX180 and front and rear mmWave radar; single S600 or dual S100P compute option. The architecture must be validated for each task.
Outdoor independent mobile development Park inspection and load transportation multiple Sensorperception system
The following describes the role of each module in the system; the actual connection depends on the selected device interface and software configuration.
01
environment perception
camera and LiDAR are combined according to field of view, distance and task; front and rear millimeter wave perception are selected according to task.
02
Integrated positioning
positioning device and vehicle status jointly serve navigation applications.
03
RDK and navigation
organizes calculation, planning, and task interfaces by model workload.
04
Luchs B chassis
performs motion and reports status through the corresponding vehicle interface.
Available range
Main vision camera: 11
Fusion positioning: positioning unit, dual GNSS antennas, independent binoculars
Provides a mobile foundation for upper-layer software and payload integration, including chassis motion, remote control and control interfaces.
4×4 mobile chassis
Remote control and host control interfaces
Payload mounting and expansion base
2.0 · Perception & autonomous navigation
11 SENSING main cameras, independent fusion positioning, 2 ATX, 4 FTX180 and front and rear mmWave radar; single S600 or dual S100P compute option. The architecture must be validated for each task.
Perception and positioning system configuration
Navigation and vehicle control integration
Mission control station and communications setup
Installation and connection conditions
The mechanical, electrical, and software interfaces between devices collectively determine system configuration.
Sensor integration
GMSL2 camera needs to match the access board and driver; LiDAR presses Data interface, synchronization and bandwidth accessories. The millimeter wave radar protocol, CAN access and host connection need to be confirmed separately.
Power distribution and installation
payload power supply, peak power consumption, installation space and center of gravity are checked according to the complete machine configuration.
control and takeover
chassis firmware, command interface, operating speed limit and manual takeover mode correspond to the navigation software.
Configure the entire solution
Select the version and number of sets, and select products in the same place. included in package, additional items and customer-supplied are listed separately.
Preparing configuration options. The complete solution will be saved as a set of products, with included in package, additional items and customer-supplied listed separately.