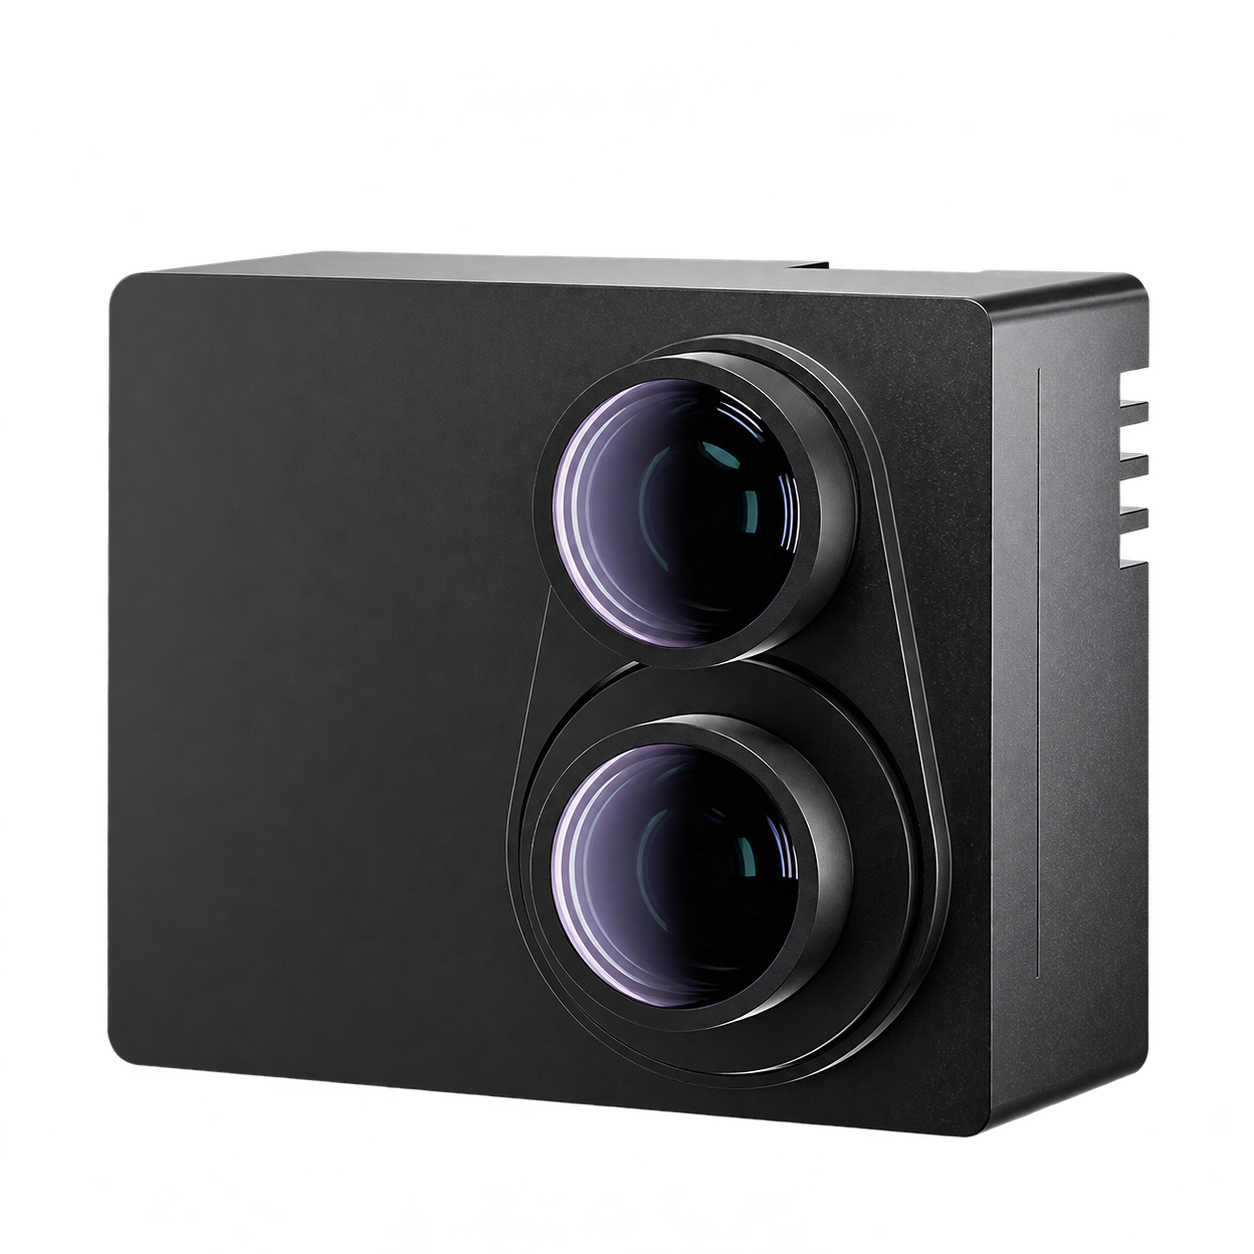
LiDAR series for directional long-distance sensing. The page organizes parameters by specification version, making it easy to choose between computing interfaces, power supply, and installation conditions.
Hardware version and corresponding parameters are presented in groups
Typical tasks
vehicle forward sensing
UGV directional point cloud collection
Multi-sensor environment awareness
What to consider
First confirm the specific specification version, and then compare channels, ranging and power consumption.
Different Ethernet physical interfaces require matching access hardware.
For the front and rear layout, the field of view and installation occlusion need to be checked separately.
Specifications & Interfaces
Switches the displayed specifications only. Purchase and inquiry configurations are selected separately.
Key specifications
Ranging distance
Ranging range: ATX_SV: 1–200 m
Nearest ranging/blind zone: 0.5 m
Conditions
10% reflectivity
Manual instrument range 0.5–198 m
10% reflectivity ranging capability 1–200 m is another caliber, unconditional guarantee if not combined
Field of view (FOV)
ATX_SV:H 120° / V 18.3°
Conditions
V -12.4°–+5.9°
Channels / Array
116 line
Angular resolution
Horizontal angular resolution: 0.08° @10 Hz
Vertical angular resolution: ROI 0.1° / non-ROI about 0.2°
Point rate
1,740,000 points/s
Frame rate
10 Hz
Ranging accuracy
Measurement accuracy: ±5 cm
Ranging repeatability: 3 cm (1σ)
Conditions
Typical value
Data interface
Data interface: 100BASE-T1, slave mode
ATX_SV interface: 100BASE-T1
Conditions
A12-en-260910
Power supply
9–16 V DC
Dimensions & Weight
Size: 102 × 102 × 30 mm
Weight: 355 g
Conditions
Width × Depth × Height
Operating environment
Temperature: −40–+85 °C
Protection: IP6K7 / IP6K9K
Additional measured specifications
Additional measured specifications
echo mode
Single echo: Last / Strongest (default)
Laser safety level
Class 1;905 nm
Other power & installation specifications
Other power & installation specifications
Other power supply parameters
Rated/Typical power consumption: 10 W
Peak and minimum power capabilities: 36 W
Conditions
Does not include connection box and other accessories
The manual requires the external power supply to provide at least 36 W
Other interfaces & features
Other interfaces & features
Point cloud data rate
64.6 / 71.7 Mbps
Conditions
Single echo average/peak
The total data rate including Ethernet overhead is 66.0/73.3 Mbps
Connectors and cables
Automotive Ethernet Connector + 4-pin TE Power Connector
Conditions
A12 manual
Synchronization
gPTP(802.1AS AUTOSAR)
System & software scope
HesaiLidar_ROS_2.0 official driver repository lists this model
Key specifications
Ranging distance
Ranging range: ATX_SV: 1–200 m
Nearest ranging/blind zone: 0.5 m
Conditions
10% reflectivity
Manual instrument range 0.5–198 m
10% reflectivity ranging capability 1–200 m is another caliber, unconditional guarantee if not combined
Field of view (FOV)
ATX_SV:H 120° / V 18.3°
Conditions
V -12.4°–+5.9°
Channels / Array
116 line
Angular resolution
Horizontal angular resolution: 0.08° @10 Hz
Vertical angular resolution: ROI 0.1° / non-ROI about 0.2°
Point rate
1,740,000 points/s
Frame rate
10 Hz
Ranging accuracy
Measurement accuracy: ±5 cm
Ranging repeatability: 3 cm (1σ)
Conditions
Typical value
Data interface
Data interface: 100BASE-T1, slave mode
ATX_SV interface: 100BASE-T1
Conditions
A12-en-260910
Power supply
9–16 V DC
Dimensions & Weight
Size: 102 × 102 × 30 mm
Weight: 355 g
Conditions
Width × Depth × Height
Operating environment
Temperature: −40–+85 °C
Protection: IP6K7 / IP6K9K
Additional measured specifications
Additional measured specifications
echo mode
Single echo: Last / Strongest (default)
Laser safety level
Class 1;905 nm
Other power & installation specifications
Other power & installation specifications
Other power supply parameters
Rated/Typical power consumption: 10 W
Peak and minimum power capabilities: 36 W
Conditions
Does not include connection box and other accessories
The manual requires the external power supply to provide at least 36 W
Other interfaces & features
Other interfaces & features
Point cloud data rate
64.6 / 71.7 Mbps
Conditions
Single echo average/peak
The total data rate including Ethernet overhead is 66.0/73.3 Mbps
Connectors and cables
Automotive Ethernet Connector + 4-pin TE Power Connector
Conditions
A12 manual
Synchronization
gPTP(802.1AS AUTOSAR)
System & software scope
HesaiLidar_ROS_2.0 official driver repository lists this model
Components & Accessories
Product & configuration scope
Selected specification versions of ATX
Corresponding interface conversion, wiring harness and installation accessories are selected from the list
Accessory selection
Model matching Ethernet access device
Power supplies, connectors and wiring harnesses
Oriented mounting surfaces and synchronization conditions
Included items, options, wiring harnesses and mounting hardware are confirmed according to the selected model and system configuration.
Software and usage support
Use the point cloud resolution configuration corresponding to the model and firmware.
Driver access, time synchronization and sensor calibration are checked separately.
The upper-layer application is configured according to the actual point cloud density and computing load.
Operating conditions
100BASE-T1 requires matching vehicle Ethernet access hardware and cannot be directly assumed to be the same as the ordinary RJ45 network port.
Power consumption, power supply margin, size and driver configuration should use the same hardware version data.
Models and optional configurations
ATX_SV · Standard version
Press A12-en-260910 manual: 116 line, 200m@10%, 10W, 100BASE-T1. The 256 line/230m/8W indicators of the official series belong to another specification range, and the parameters are matched according to the specific material number when selecting.