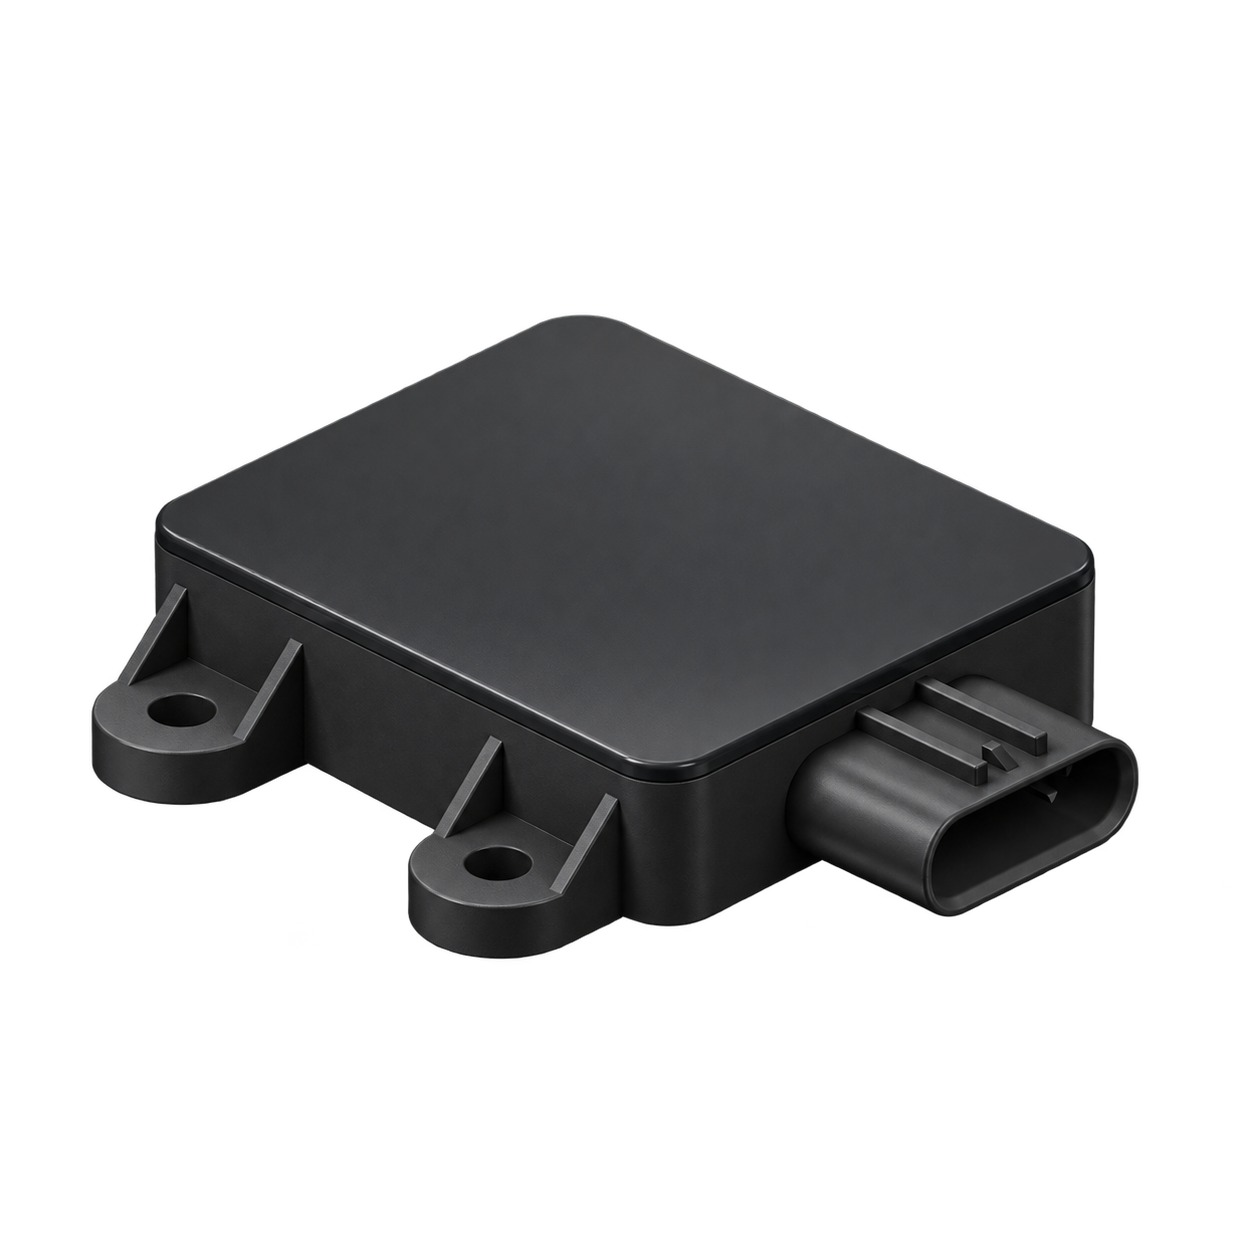
The front and rear blind zone supplementary sensing millimeter wave radar for automotive-grade applications can be used for the selection of sensing systems for vehicles and unmanned vehicles.
Placeholder Appearance reference · Not the exact model · Not a photograph
Overview
Exact model BSR403T3
UGV front and rear perception optional
CAN access and complete accessories are confirmed separately
Typical tasks
UGV Optional configurations of front and rear perception
Check the accessories of the existing vehicle perceptionpayload
What to consider
First describe the vehicle, front and rear installation positions, quantity and existing computing equipment, and then confirm the complete model and hardware version.
describes the vehicle interface, existing access equipment and upper-layer application requirements.
already has a wiring harness, Power supply or access device, please record the exact model number; the components in the set will not be purchased repeatedly, and additional spare parts will be listed separately.
Specifications & Interfaces
Switches the displayed specifications only. Purchase and inquiry configurations are selected separately.
Key specifications
Installation and quantity range
It can be organized and configured according to 1 units in the front and 1 units in the rear.
Conditions
The quantity corresponds to the before and after plans
Key specifications
Installation and quantity range
It can be organized and configured according to 1 units in the front and 1 units in the rear.
Conditions
The quantity corresponds to the before and after plans
Components & Accessories
Accessory selection
Match harnesses, connectors, pin-outs and CAN interfaces to the exact hardware version.
Check supply conditions, vehicle power distribution, branch protection and grounding.
Confirm the bracket, shielding, installation direction, cable path and calibration conditions according to the front and rear installation positions.
Included items, options, wiring harnesses and mounting hardware are confirmed according to the selected model and system configuration.
Software and usage support
After confirming the communication protocol, message definition, driver and system version, verify the data reading, time stamp and vehicle coordinate system.
Sensor data access, target detection and multi-Sensor fusion algorithms, and vehicle autonomous driving are verified separately.
Operating conditions
confirms the usage range based on the front and rear installation positions, occlusion, coordinate system and task scenarios.
CAN data access, target detection and multi-Sensor fusion algorithm, and autonomous driving of the vehicle are verified separately; the overall machine capability cannot be inferred from component selection.
Check CAN protocol, drivers and synchronisation for the selected host and radar version.
Models and optional configurations
BSR403T3·Package is confirmed by project
Confirm package contents, CAN connection, power and mounting for the exact hardware version.

 Germany
 Netherlands
 Switzerland
 Austria
 Norway
 Finland