Fixposition · Positioning and inertial measurement
Fixposition Vision-RTK 2
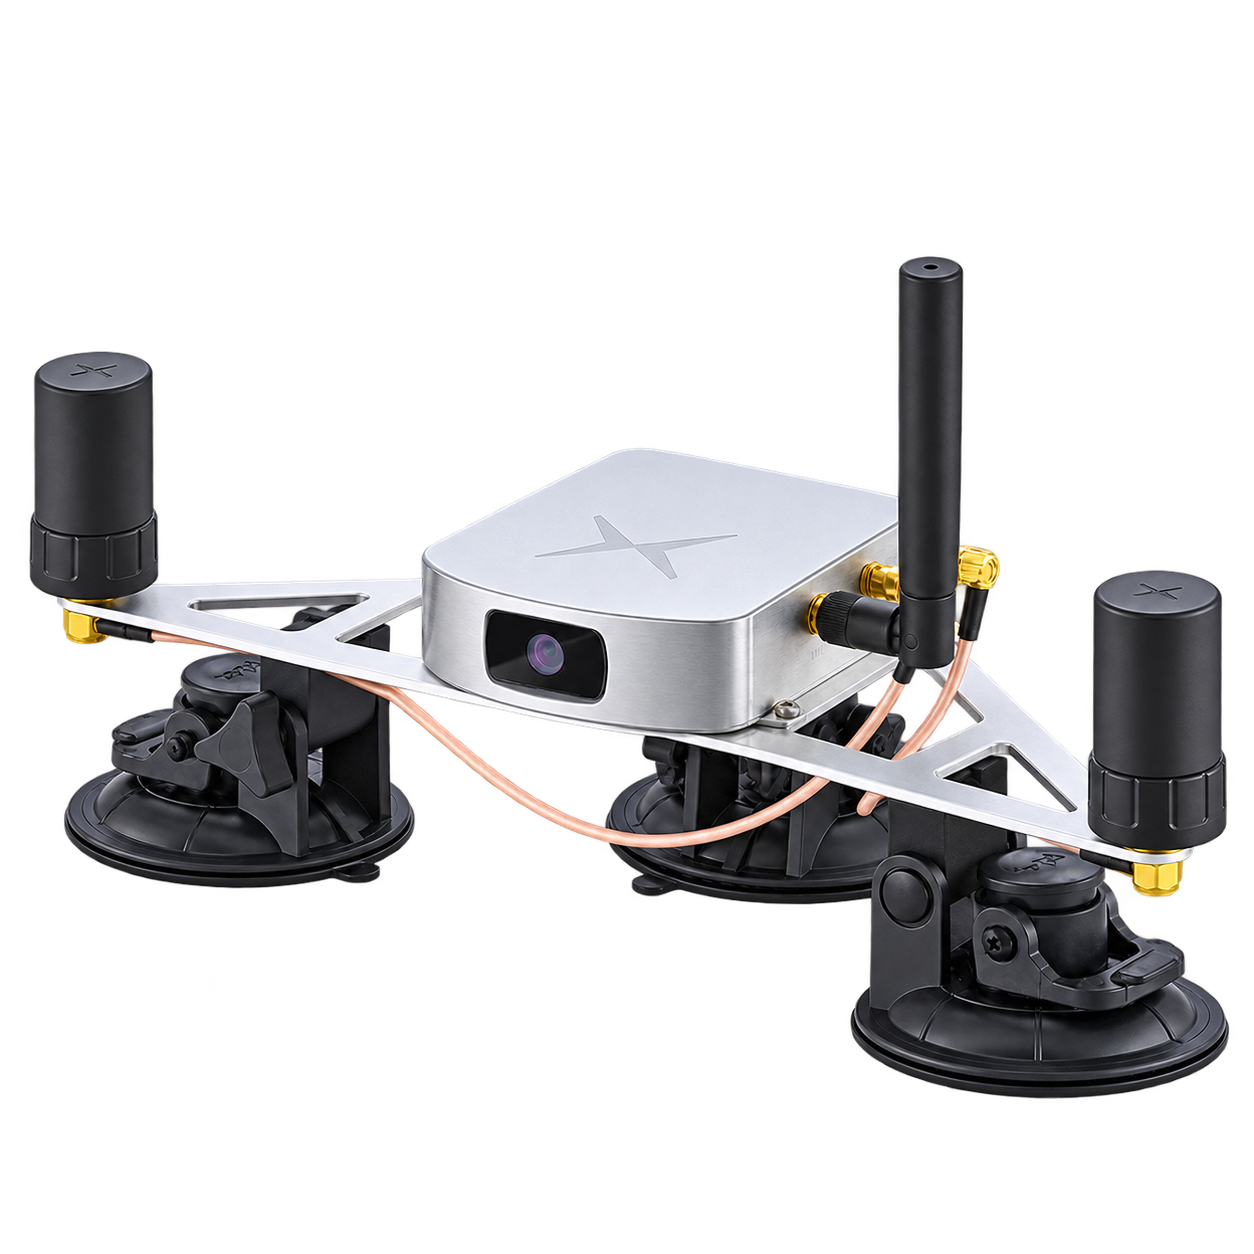
A positioning device that combines vision, GNSS and inertial information, suitable for mobile robots to obtain continuous position and motion information. It is necessary to plan the equipment installation, GNSS antenna and correction data at the same time when using it.
Vision / GNSS / IMU Fusion method
2 multi-frequency RTK receivers GNSS
ROS 1 / ROS 2 Software resources
Overview
- 2 multi-frequency RTK GNSS receiver
- Fusion of vision, inertia, satellite navigation and wheel speed
- Ethernet / Wi-Fi TCP/IP and serial data output
- Official ROS 1 / ROS 2 Driver and Data Tools
Typical tasks
- Outdoor robot positioning
- GNSS and visual-assisted positioning
- Mobile platform navigation data input
What to consider
- Evaluate positioning conditions based on sky visibility, visual texture, and mission route.
- Positioning accuracy should be understood in conjunction with the RTK status and test conditions.
- When installing, consider the relationship between the antenna baseline, equipment field of view and vehicle body coordinates.
Specifications & Interfaces
| GNSS and RTK configuration | 2 multi-frequency RTK GNSS receiver |
|---|---|
| Visual layout and access | for visual tracking and odometry |
| Measurement accuracy | Positioning accuracy: 1.0 cm + 1 ppm R50
Heading accuracy: 0.4° Conditions
|
| Output frequency and delay | Maximum 100 Hz |
| Fusion and auxiliary input | Fusion input: VIO, GNSS, wheel speed and auxiliary sensors
Auxiliary input: wheel speed odometer
Drive input: RTCM differential data, wheel speed |
| Positioning output and reference system | Global position, attitude, velocity and corresponding covariance |
| Data interface | Data communication: Ethernet TCP/IP, Wi-Fi TCP/IP, serial interface
Driver communication: TCP / Serial |
| Power supply | 5–36 V DC Conditions
|
| Dimensions & Weight | Size: 114 × 129 × 30 mm
Weight: 420 g Conditions
|
| Operating environment | Temperature: −30–+85 °C
Protection: IP66 |
Additional measured specifications
| Speed accuracy | 0.1 m/s |
|---|---|
| GNSS Lockout position deviation and conditions | 0.75% of distance traveled Conditions
|
Additional memory & Storage
| Storage & Expansion | 16 GB flash |
|---|
Other power & installation specifications
| Other power supply parameters | 10 W Conditions
|
|---|
Other interfaces & features
| Differentiated Service Conditions | Use third-party differential services such as NTRIP |
|---|---|
| Connectors and cables | 2×SMA |
| Synchronization | PPS / PTP / NTP |
| System & software scope | ROS access: ROS 1 / ROS 2 official driver
Data tools: Fixposition SDK / Utility |
| Configuration and logging | Browser configuration interface, internal data logging |
Components & Accessories
Product & configuration scope
- Vision-RTK 2 positioning unit
- Complete with GNSS antenna and connecting cable according to integrated configuration
Accessory selection
- Matching GNSS antenna and cable
- RTK Correct data source and network connection
- Fixed mounting surface, power and data cables
Included items, options, wiring harnesses and mounting hardware are confirmed according to the selected model and system configuration.
Software and usage support
- Positioning messages can be read through the official ROS driver.
- The docking system unifies the coordinate system, timestamp and message frequency.
- Auxiliary inputs such as wheel speed are configured according to the device documentation and platform interface.
Operating conditions
- GNSS The antenna and camera are rigidly installed, and the external parameters and wheel speed configuration are completed; visual tracking requires an effective field of view.
- RTK Differentiated services are configured independently of network connectivity; on-site positioning performance depends on satellite, vision and installation conditions.
Technical resources
Fixposition documentation and development resources Official documentation ↗ Vision-RTK 2 / PBx-A1 product overview View product information ↗ Fixposition ROS 1 / ROS 2 driver Drivers and examples ↗ Fixposition data SDK Drivers and examples ↗ Vision-RTK 2 software version compatibility table 2.123.7 · 2026-05 Official documentation ↗ Fixposition official support: Vision-RTK 2 View product information ↗ Vision-RTK 2 official public product brochure Rev.5_D03 View product information ↗
When using these documents, please check the product model, hardware configuration and document version.
Learn about related components
Explore the compute, perception and mobile platforms used in related solutions; see each solution for compatibility conditions and options.