
Odin1 Lite · V0.1.4 Manual Specifications
This page is for Lite models: 274g, 1280×1088 RGB, up to 10fps. The Dimensions, image and ranging parameters of the Odin1 series Other model do not apply to this model.
 Germany
 Netherlands
 Switzerland
 Austria
 Norway
 Finland
MindPalace Shape Retaining Technology · 3D sensor fusion
A compact sensor that combines dToF depth sensing with a RGB camera to provide depth, image and color point cloud related data for robots to understand three-dimensional environments.
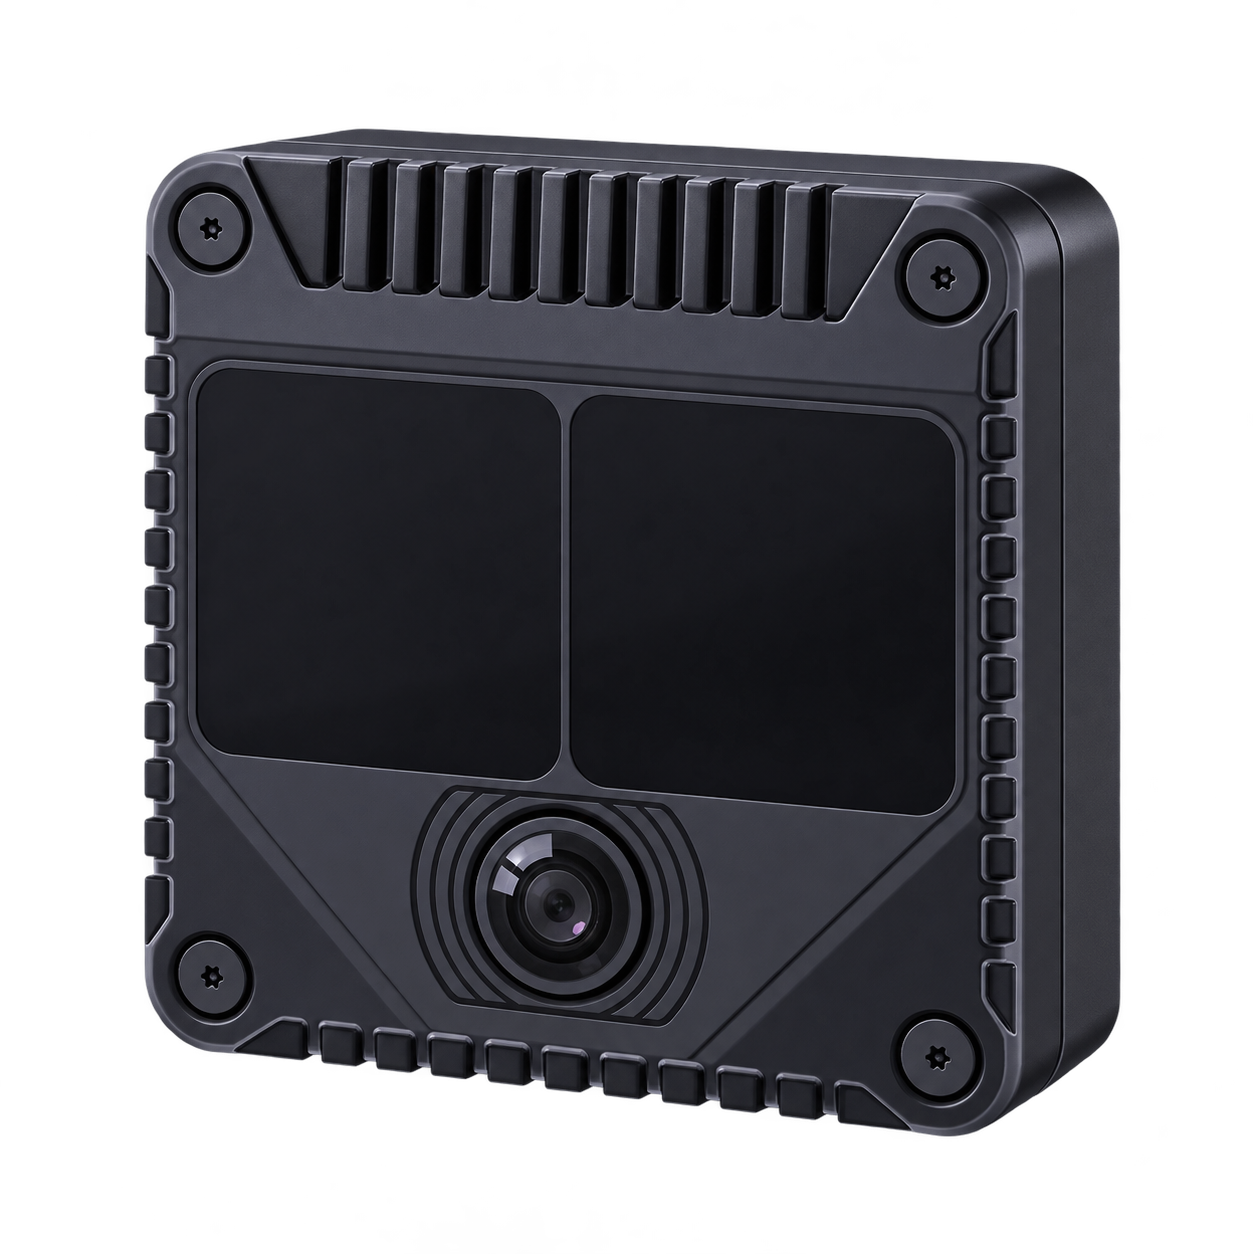
Switches the displayed specifications only. Purchase and inquiry configurations are selected separately.
| Depth resolution | 240 × 180 |
|---|---|
| Depth field of view FOV | 120° × 90° |
| Depth ranging range | Ranging range: Ranging (10% reflectivity): 25 m
Ranging (90% reflectivity): 50 m
Recent ranging: 0.15 m Conditions
|
| Frame rate | 10 fps |
| RGB Imaging | RGB Imaging: 1280 × 1088
RGB shutter: global shutter
RGB Field of view: 121° H × 106° V × 151° D |
| data output | True color SLAM / original point cloud, RGB image, IMU and pose |
| Data interface | 1000BASE-T Gigabit Ethernet |
| Power supply | 9–24 V DC |
| Dimensions & Weight | Size: Approximately 69 × 69 × 58 mm
Weight: 274 g Conditions
|
| Operating environment | Temperature: −20–+65 °C
Protection: IP66 |
| Depth ranging accuracy | ±3 cm @1σ Conditions
|
|---|---|
| SLAM accuracy and applicable conditions | ±5 cm + 1% Conditions
|
| Laser wavelength and safety level | Laser wavelength: 940 nm
Laser safety level: Class 1 |
| Other power supply parameters | Rated/Typical power consumption: 11 W
Peak and minimum power capabilities: 24 W |
|---|
| Angular resolution | 0.5° × 0.5° |
|---|---|
| Point rate | 430,000 points/s |
| Connectors and cables | 12 core aviation plug, power and data are divided into two lines |
| System & software scope | Software interface: SDK / ROS 1 / ROS 2
ROS system combination: Ubuntu 20.04 / Noetic; 22.04 / Humble; 24.04 / Jazzy Conditions
|
| Depth resolution | 240 × 180 |
|---|---|
| Depth field of view FOV | 120° × 90° |
| Depth ranging range | Ranging range: Ranging (10% reflectivity): 25 m
Ranging (90% reflectivity): 50 m
Recent ranging: 0.15 m Conditions
|
| Frame rate | 10 fps |
| RGB Imaging | RGB Imaging: 1280 × 1088
RGB shutter: global shutter
RGB Field of view: 121° H × 106° V × 151° D |
| data output | True color SLAM / original point cloud, RGB image, IMU and pose |
| Data interface | 1000BASE-T Gigabit Ethernet |
| Power supply | 9–24 V DC |
| Dimensions & Weight | Size: Approximately 69 × 69 × 58 mm
Weight: 274 g Conditions
|
| Operating environment | Temperature: −20–+65 °C
Protection: IP66 |
| Depth ranging accuracy | ±3 cm @1σ Conditions
|
|---|---|
| SLAM accuracy and applicable conditions | ±5 cm + 1% Conditions
|
| Laser wavelength and safety level | Laser wavelength: 940 nm
Laser safety level: Class 1 |
| Other power supply parameters | Rated/Typical power consumption: 11 W
Peak and minimum power capabilities: 24 W |
|---|
| Angular resolution | 0.5° × 0.5° |
|---|---|
| Point rate | 430,000 points/s |
| Connectors and cables | 12 core aviation plug, power and data are divided into two lines |
| System & software scope | Software interface: SDK / ROS 1 / ROS 2
ROS system combination: Ubuntu 20.04 / Noetic; 22.04 / Humble; 24.04 / Jazzy Conditions
|
Included items, options, wiring harnesses and mounting hardware are confirmed according to the selected model and system configuration.
This page is for Lite models: 274g, 1280×1088 RGB, up to 10fps. The Dimensions, image and ranging parameters of the Odin1 series Other model do not apply to this model.
When using these documents, please check the product model, hardware configuration and document version.
Explore the compute, perception and mobile platforms used in related solutions; see each solution for compatibility conditions and options.
 D-Robotics RDK S100P Compute & control D-Robotics RDK S100 Compute & control
 DEEP Robotics X30 Quadruped & wheeled-legged robots
 DEEP Robotics LYNX M20 Quadruped & wheeled-legged robots
 TerraAgent Quadruped Perception & Positioning Payload Perception & positioning payloads
 Other RJ autonomy and robot system integration services Customization & integration