
D-Robotics RDK X5
- Hosts listed by the manufacturer
- D-Robotics RDK X5
 Germany
 Netherlands
 Switzerland
 Austria
 Norway
 Finland
D-Robotics D-Robotics · Vision camera
The binocular global shutter camera integrating ICM-42688-P IMU is connected to RDK through two MIPI for binocular perception and motion information collection.
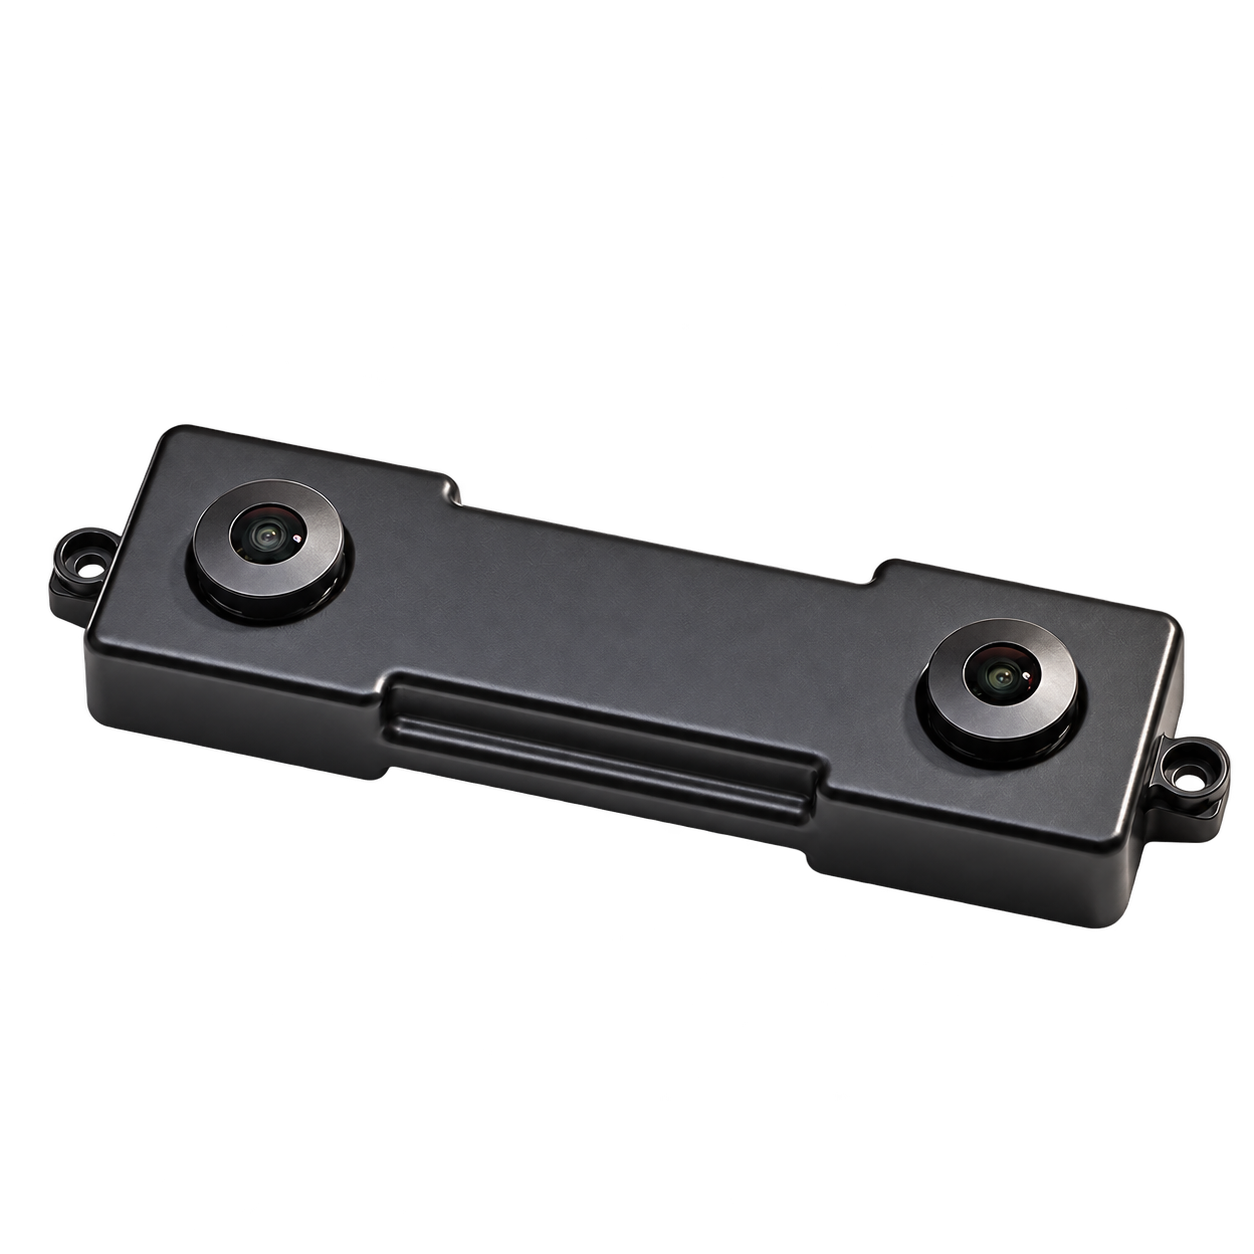
Official RDK accessories
Supported hosts and connections are listed in the manufacturer's documentation.
| Resolution | 1080 × 1280 px Conditions
|
|---|---|
| Field of view (FOV) | H 96.8° / V 115.6° / D 157.2° |
| Output format | RAW RGB 12 / 10 / 8 bit |
| Shutter | Global shutter |
| Stereo baseline | 70 mm |
| Data interface | MIPI CSI-2(2-lane) |
| Power supply | MIPI interface PIN22: 3V3 Conditions
|
| Dimensions & Weight | Main body plane 100 × 29 mm; with mounting ears horizontal 112.86 mm |
| Sensor | Dual SC132GS |
|---|---|
| Inertial measurement | Integrated IMU: ICM-42688-P
IMU range: gyroscope ±15.625 / 31.25 / 62.5 / 125 / 250 / 500 / 1000 / 2000 dps; accelerometer ±2 / 4 / 8 / 16 g
IMU noise: gyroscope 2.8 mdps/√Hz; accelerometer 70 μg/√Hz |
| Other imaging features | HDR; signal-to-noise ratio 40 dB; 850/940 nm near-infrared enhancement |
| Frame rate | 120 fps Conditions
|
|---|---|
| data transfer rate | 2.4 Gbps |
| Connectors and cables | connector: two-way 22-pin, 0.5 mm pitch FFC/FPC
Connector model: left and right MIPI: AFC24-S22FIA-00; external interrupt: 5063-3AWB
The contact direction on the camera side of Conditions
|
| Synchronization | Binocular simultaneous exposure; supports external triggering Conditions
|
| System & software scope | TogetheROS.Bot (TROS); hobot_mipi_cam binocular acquisition example |
Included items, options, wiring harnesses and mounting hardware are confirmed according to the selected model and system configuration.
When using these documents, please check the product model, hardware configuration and document version.